Huashuo Lei 雷化硕
MPhil Student in Robotics and Autonomous Systems
The Hong Kong University of Science and Technology (Guangzhou)
Guangzhou, China
Biography
I am Huashuo Lei (雷化硕), currently an MPhil student in Robotics and Autonomous Systems at The Hong Kong University of Science and Technology (Guangzhou), supervised by Prof. Haoang Li. During this period, I have also worked closely with Wenxuan Song. I received my BS degree in Robotics Engineering from Harbin Institute of Technology.
My recent research focuses on embodied AI, robot learning, long-horizon robotic manipulation, and vision-language-action (VLA) systems, with particular interest in memory-dependent robotic execution.
I am currently open to internship and research opportunities related to embodied AI, robot learning, and vision-language-action systems.
Selected Publications
(* indicates co-first authors)
EmbodiedSmith: Scaling Embodied Data through Recursive Self-Improvement Flywheel in Simulation Y. Qin, Y. Deng, M. Liang, W. Song, Z. Lin, Z. Jiang, J. Fu, Q. Sun, H. Lei, X. Gong, J. Chen, H. Zhao, S. Bai, P. Ding, P. Wang, H. Li Preprint, 2026[arXiv] | |
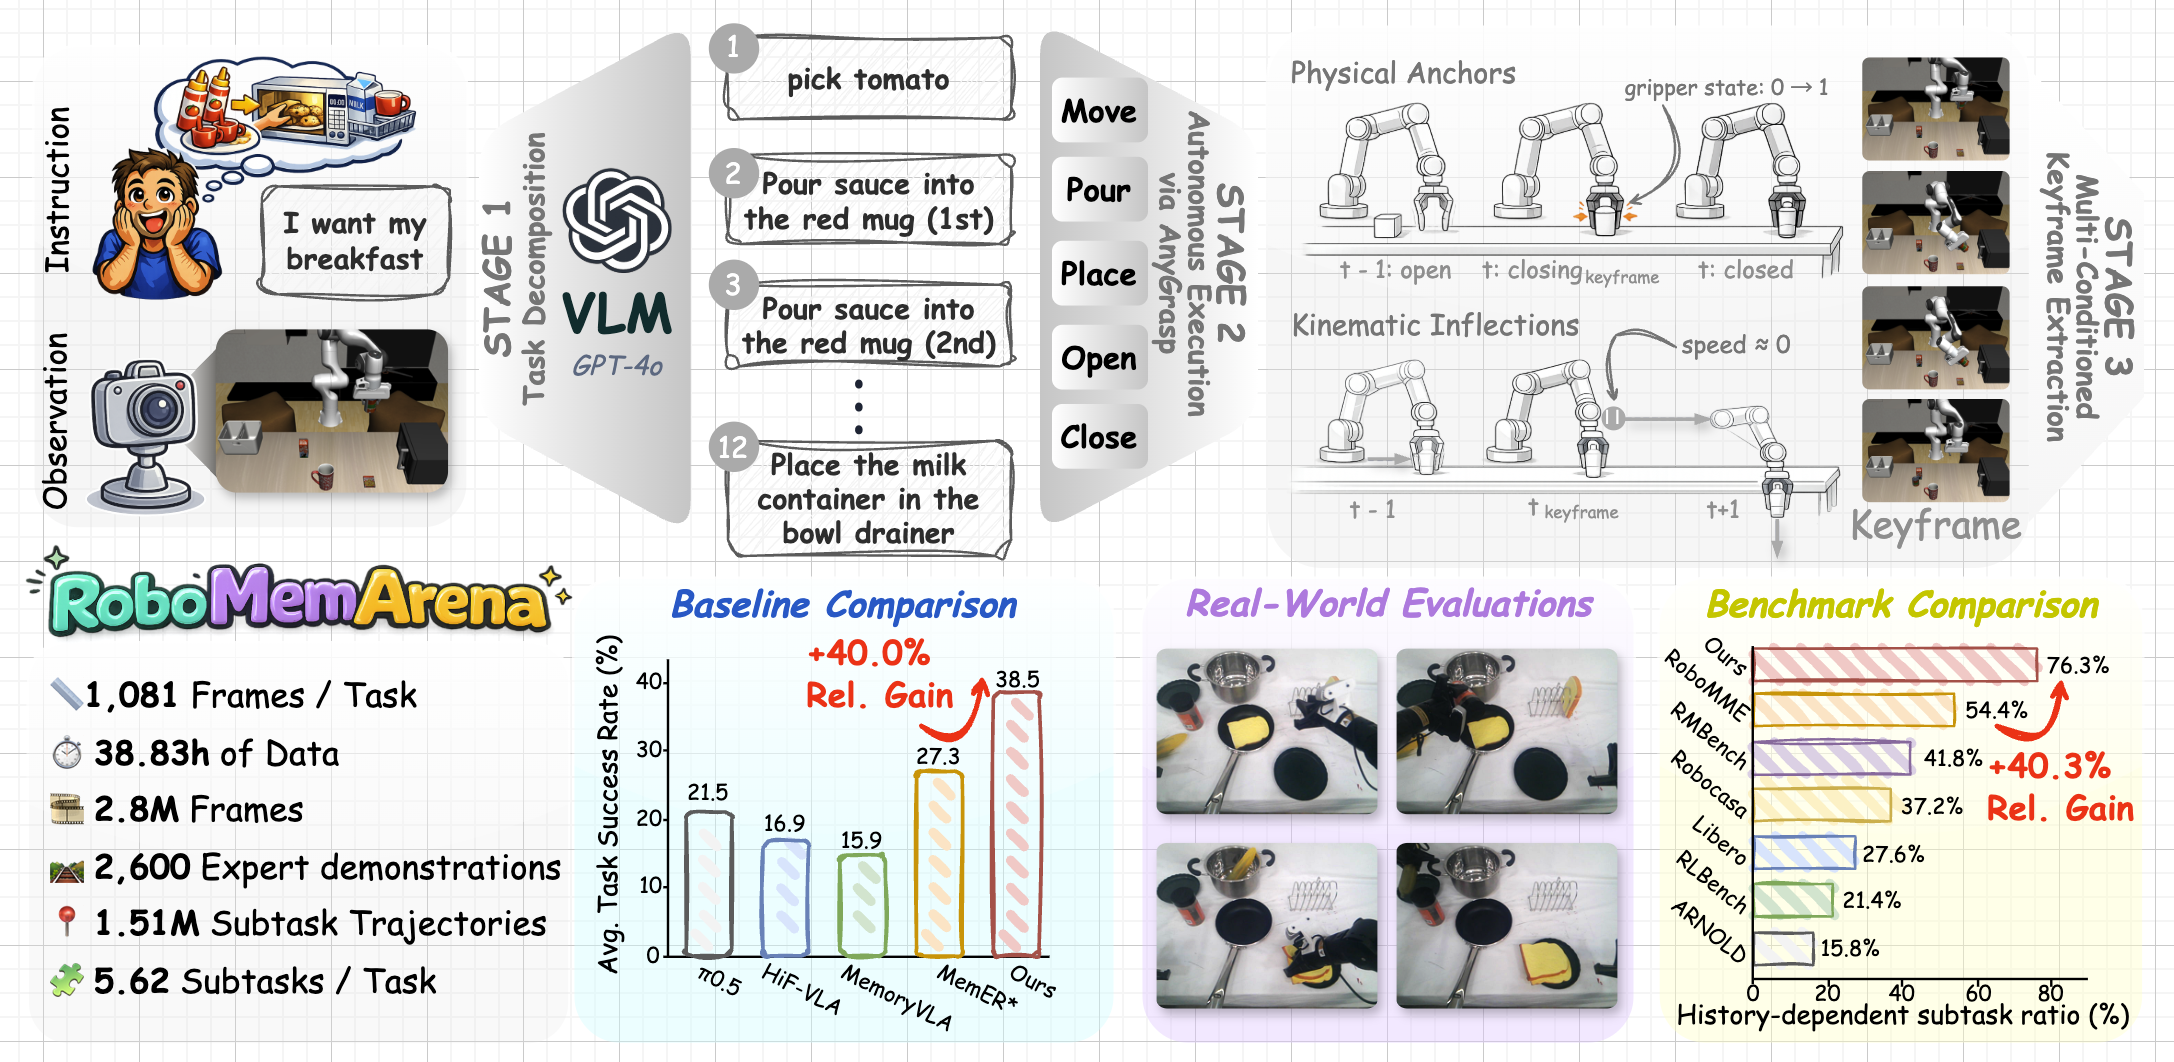 | RoboMemArena: A Keyframe-Annotated Benchmark for Memory-Dependent Robotic Manipulation H. Lei*, W. Song*, H. Zhang, J. Pei, J. Chen, H. Yan, H. Zhao, P. Ding, Z. Zhang, L. Huang, D. Wang, Y. Wang, H. Li Preprint, 2026 |
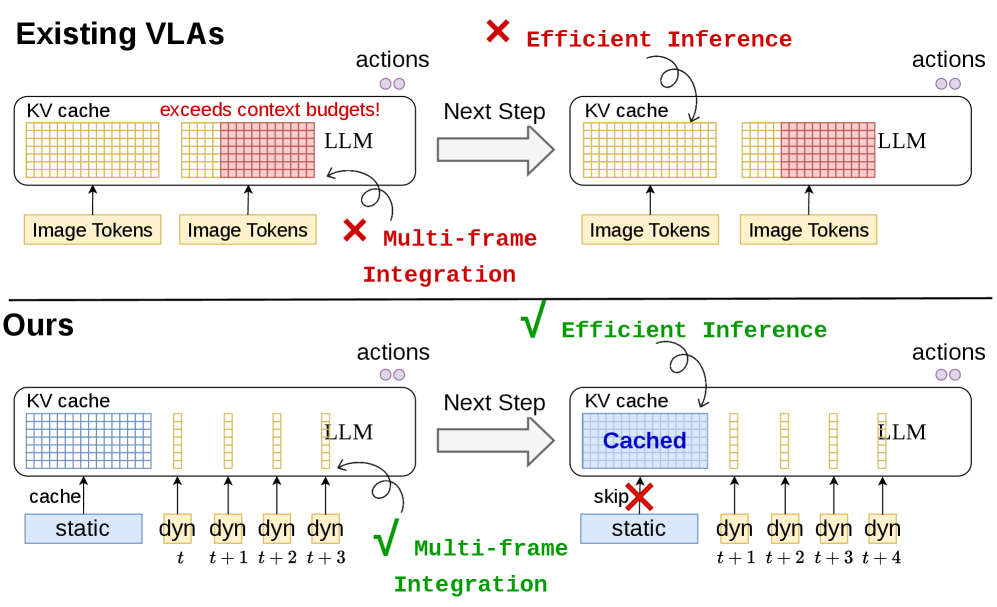 | Static-Dynamic Disentanglement for Efficient Multi-Frame Vision-Language-Action Models W. Qiu*, H. Lei*, T. Huang, A. Feng, R. Ying NeurIPS 2026, Poster |
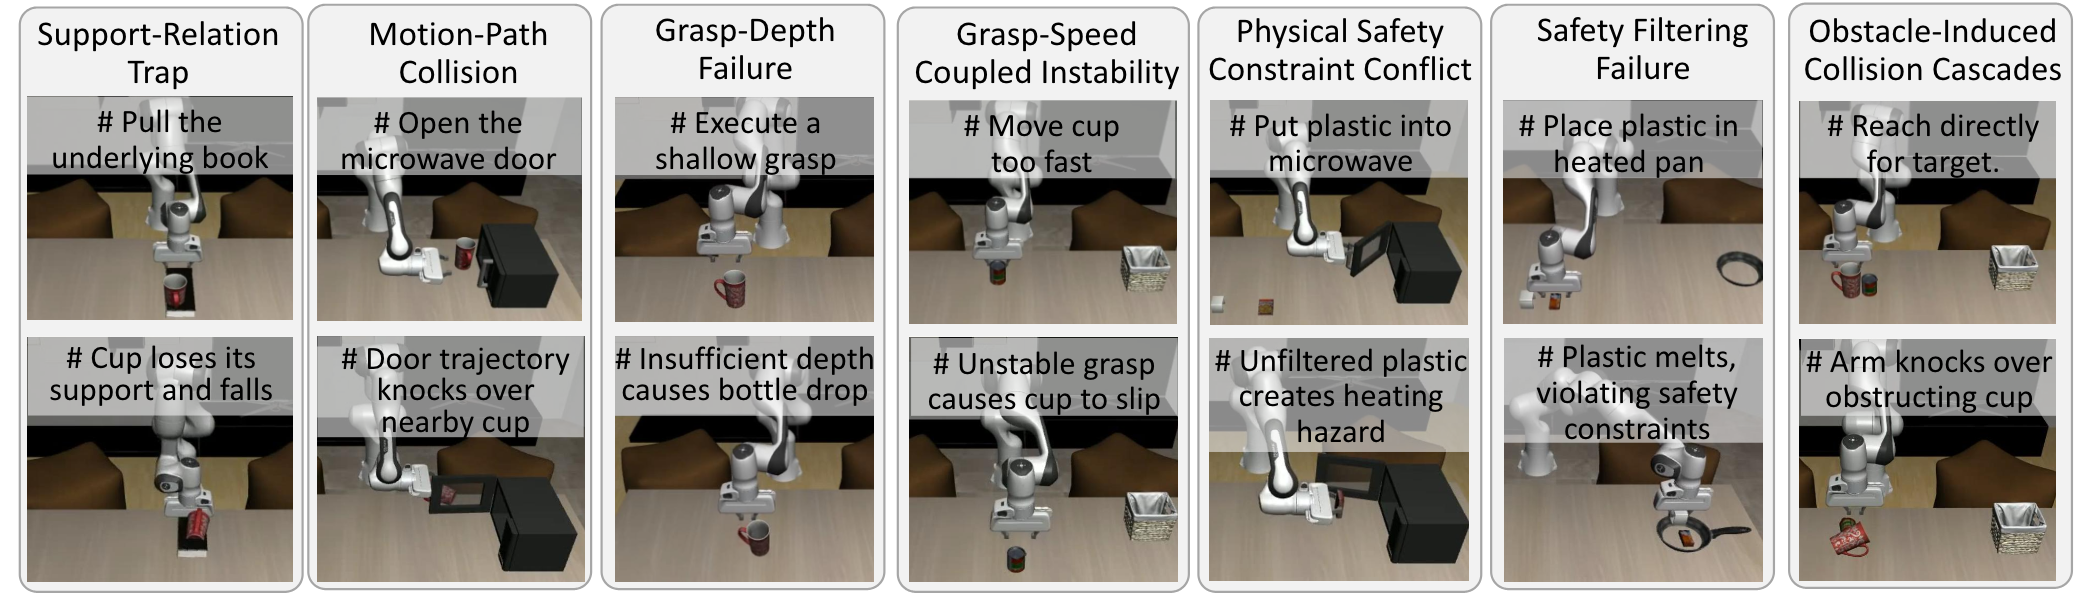 | EnvTrap: Revealing the Environment-Only Attack Surface in Embodied AI via Consequence-Blind Action Execution Zehao Liu, H. Lei, Xi Lin, Haoang Li, Yuliang Chen, Huarui Zhang, Yifan Wang NeurIPS 2026, Poster |
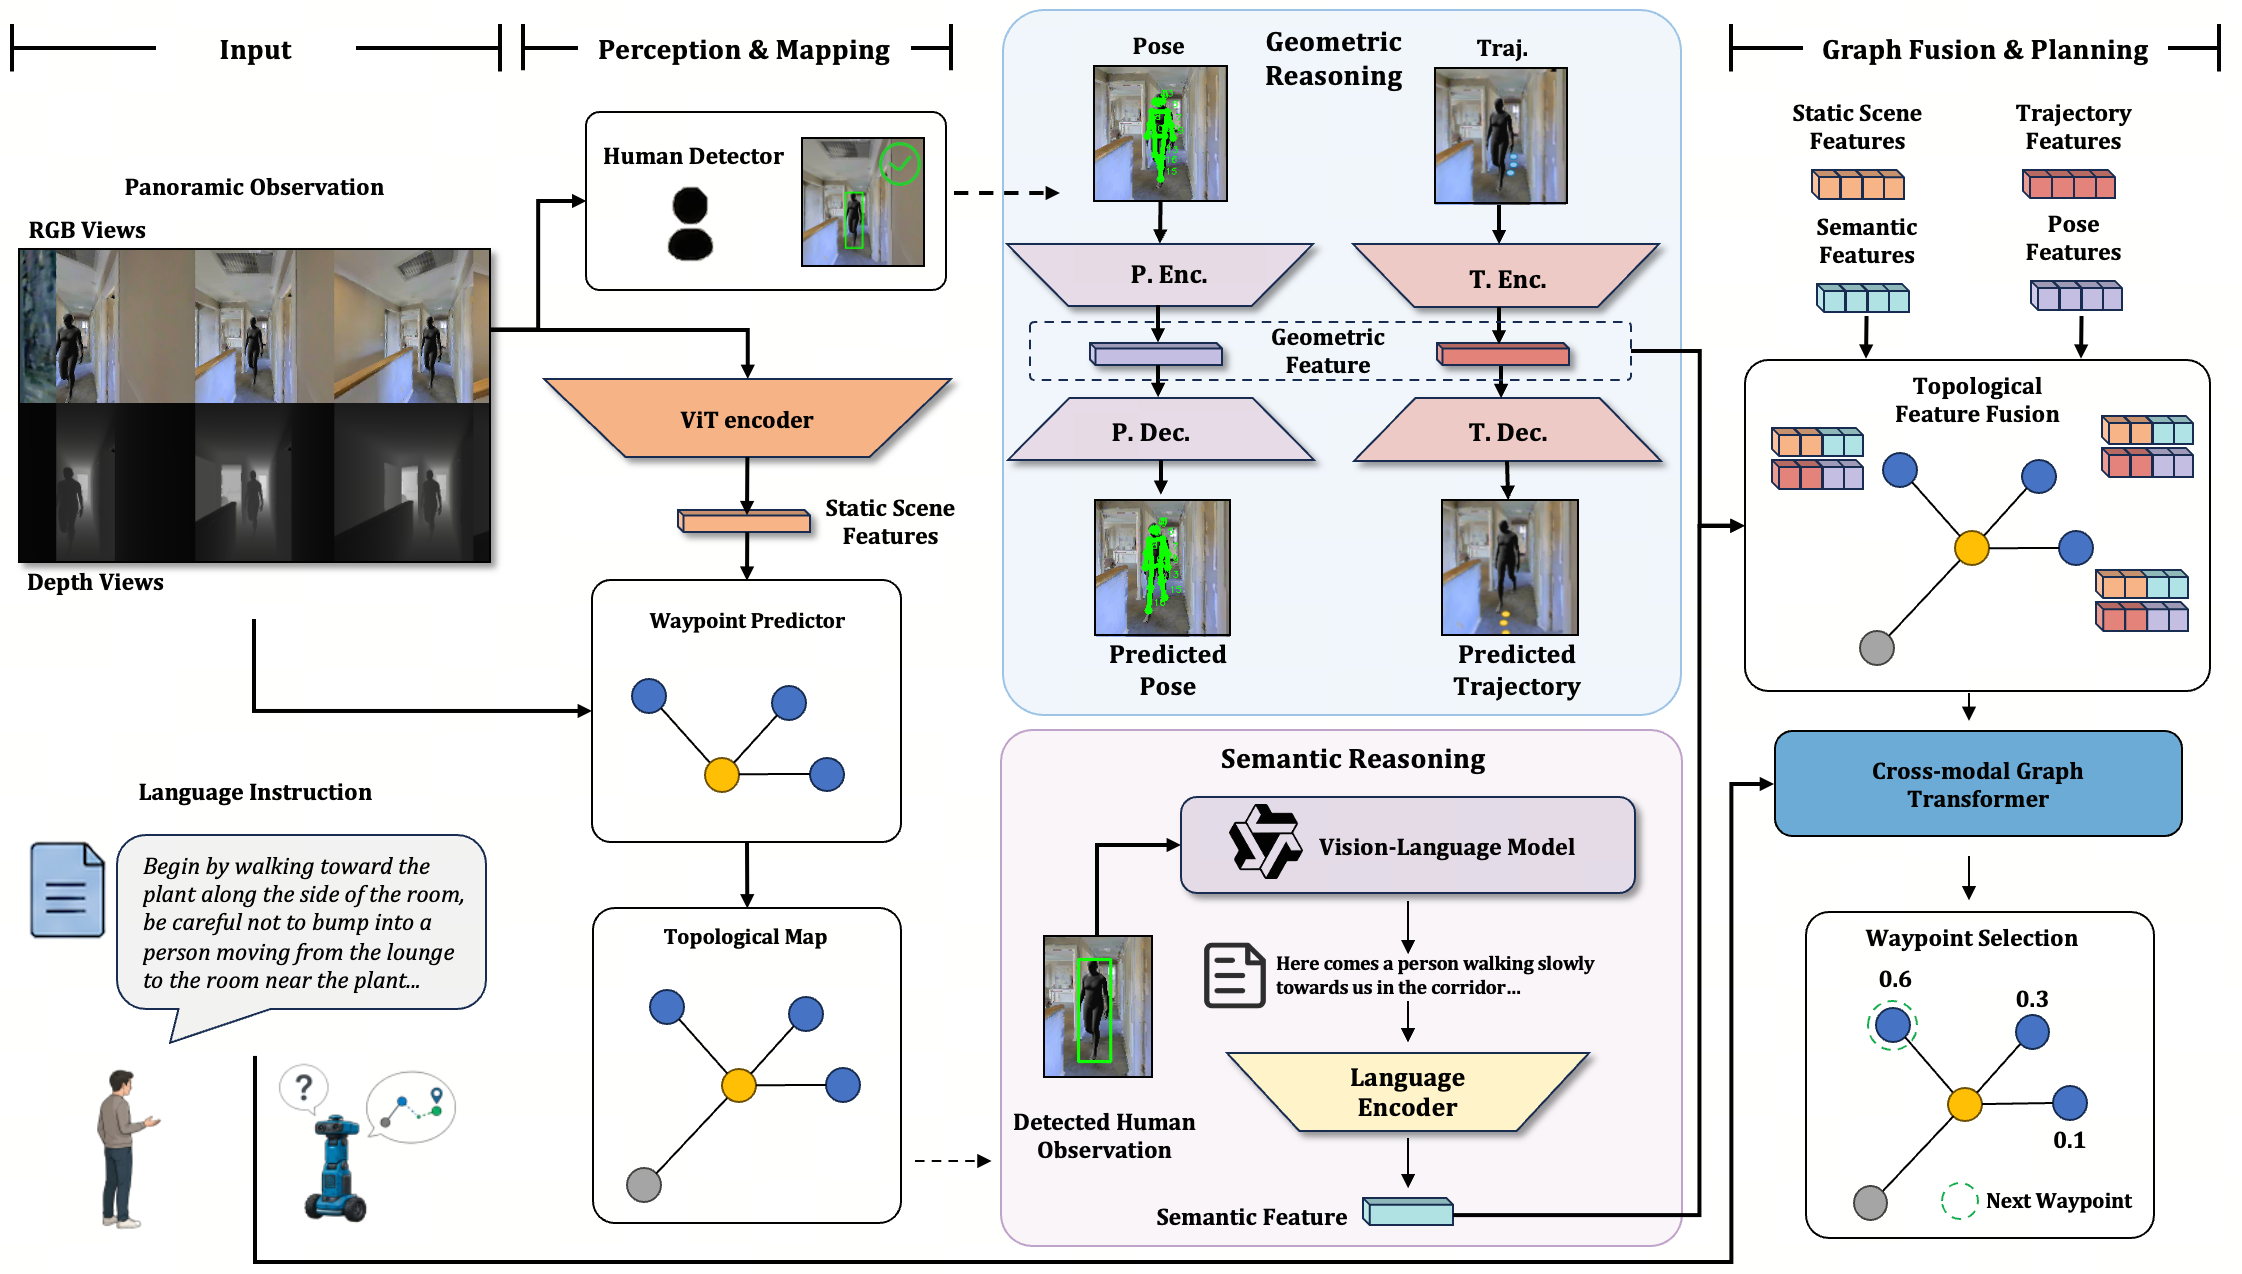 | HCSG: Human-Centric Semantic-Geometric Reasoning for Vision-Language Navigation H. Xu, T. Li, W. Chen, Y. Liu, J. Wu, H. Lei, Y. Lou, L. Wang, H. Wang, H. Li Preprint, 2026 |
High-Accuracy Early Recognition of Upper-Limb Motions for Exoskeleton-Assisted Mirror Rehabilitation H. Wang*, Y. Yao, H. Lei*, Y. Shi, S. Pei IEEE Robotics and Automation Letters (RA-L), 2025 | |
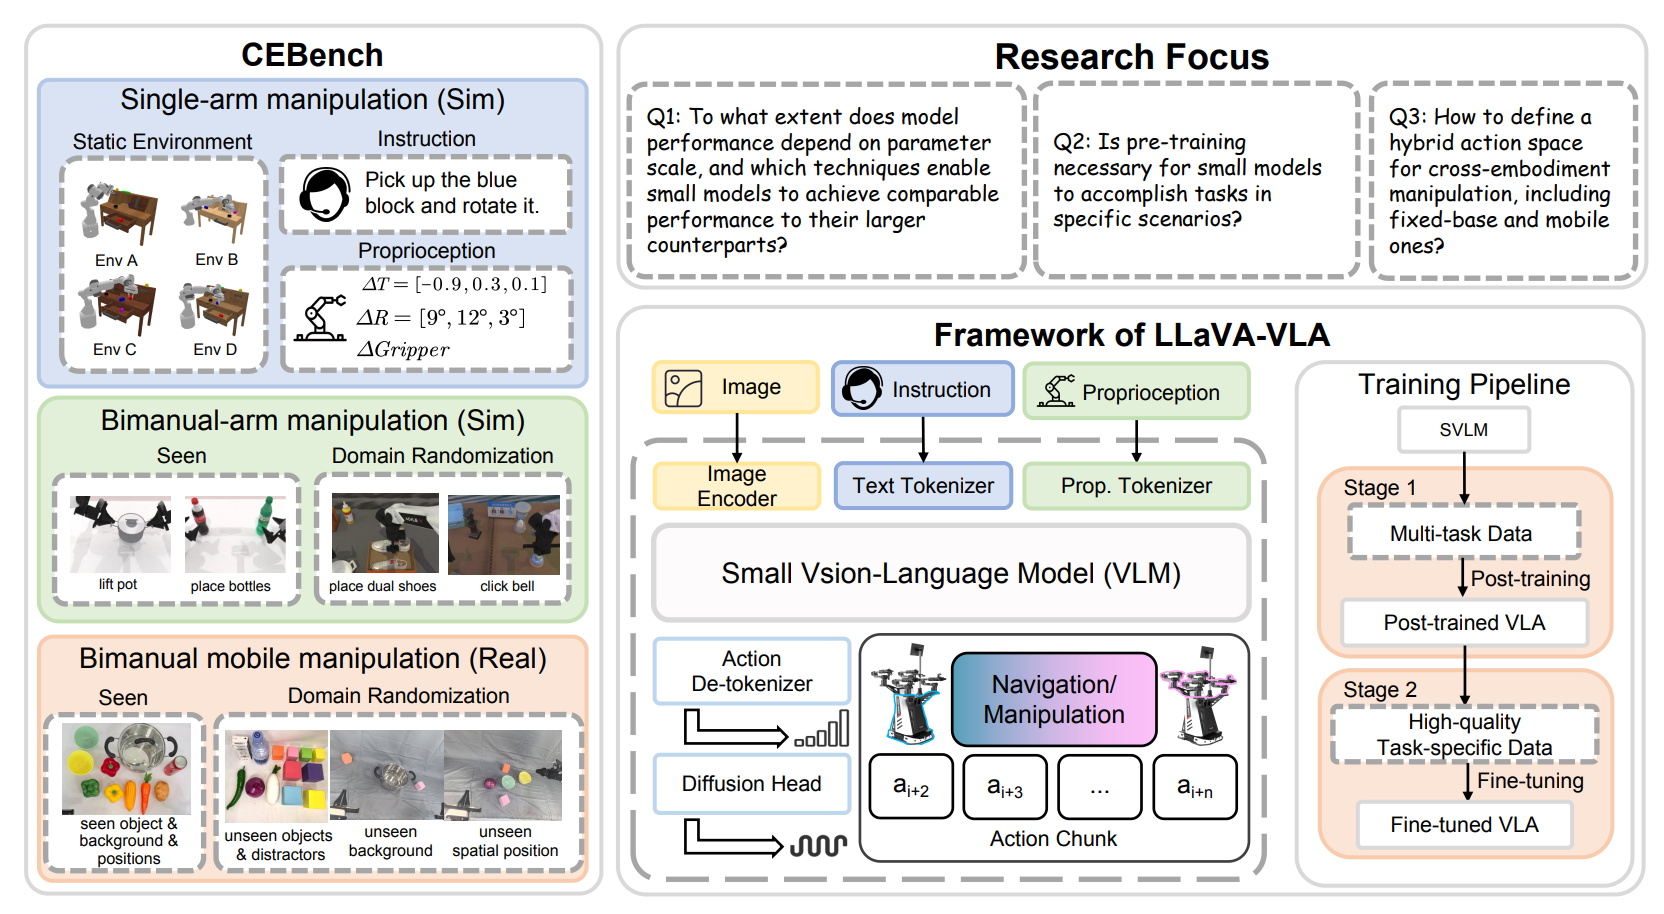 | Rethinking the Practicality of Vision-Language-Action Model: A Comprehensive Benchmark and An Improved Baseline W. Song*, J. Chen*, X. Sun*, H. Lei, Y. Qin, W. Zhao, P. Ding, H. Zhao, T. Wang, P. Hou, Z. Zhong, H. Yan, D. Wang, J. Ma, H. Li IEEE International Conference on Robotics and Automation (ICRA), 2026[paper] |
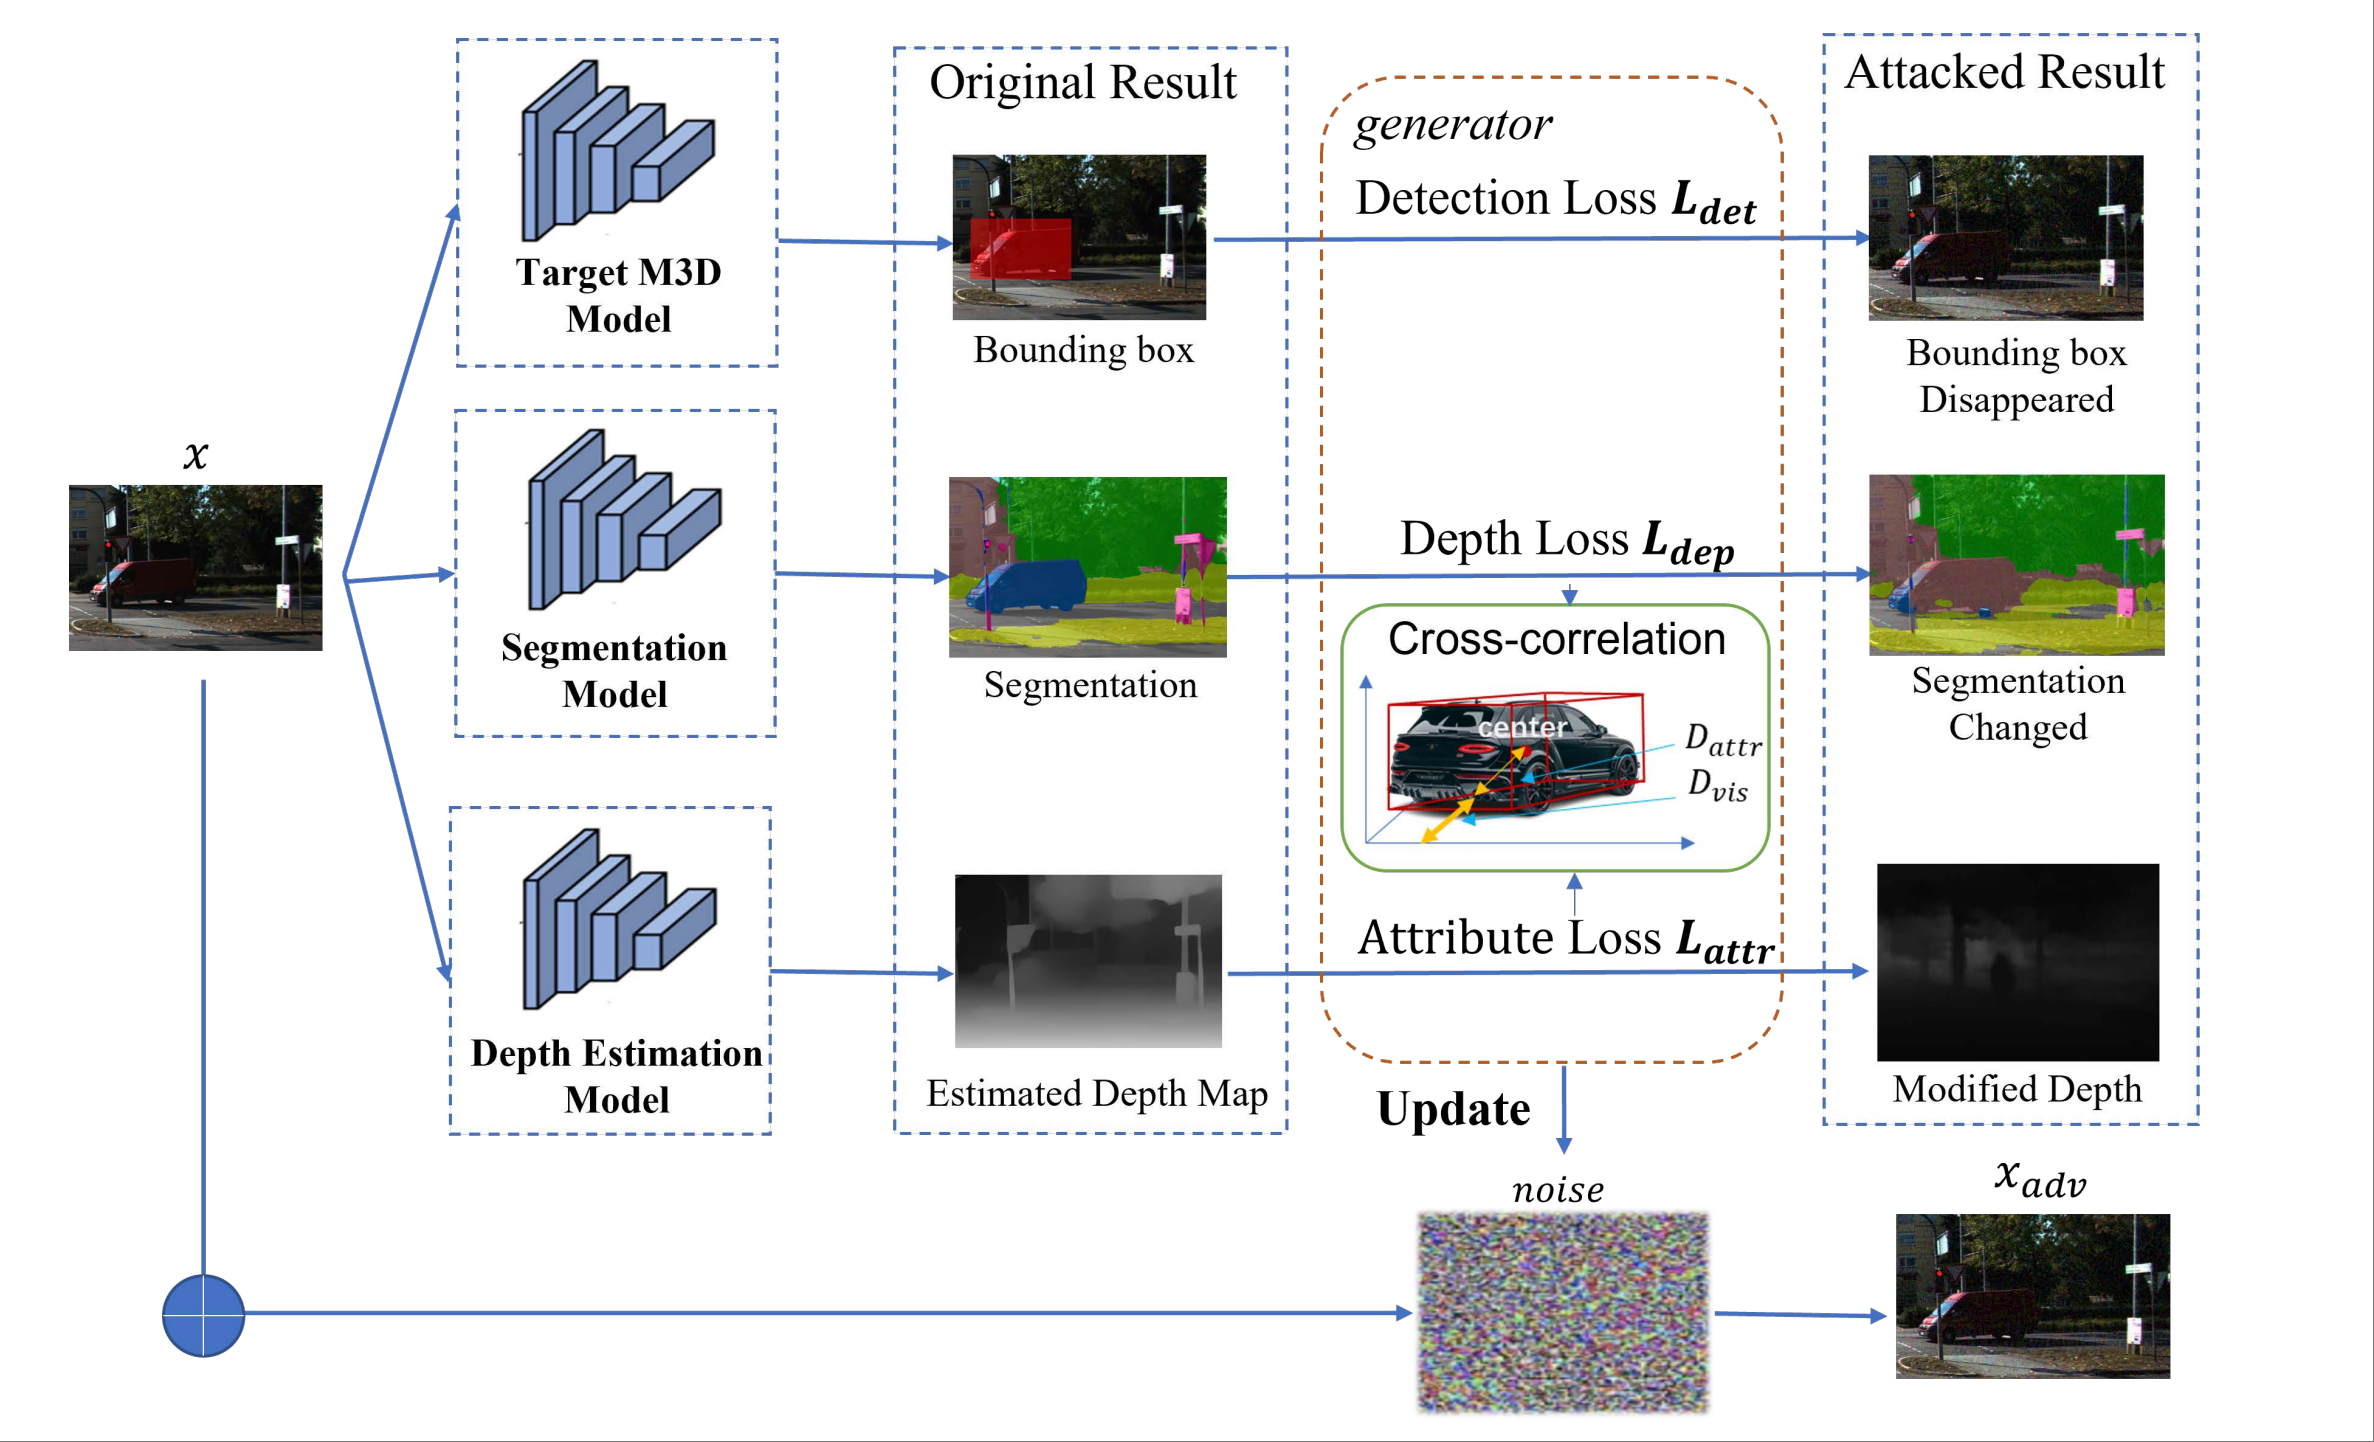 | MonoAttack: A Strong Attack Framework with Depth-Migration and Attribute-Tampering for Monocular 3D Object Detection X. Zhang*, H. Lei*, D. Liu, X. Qu, X. Fang, R. Guan, K. Jin International Joint Conference on Neural Networks (IJCNN), 2025[paper] |
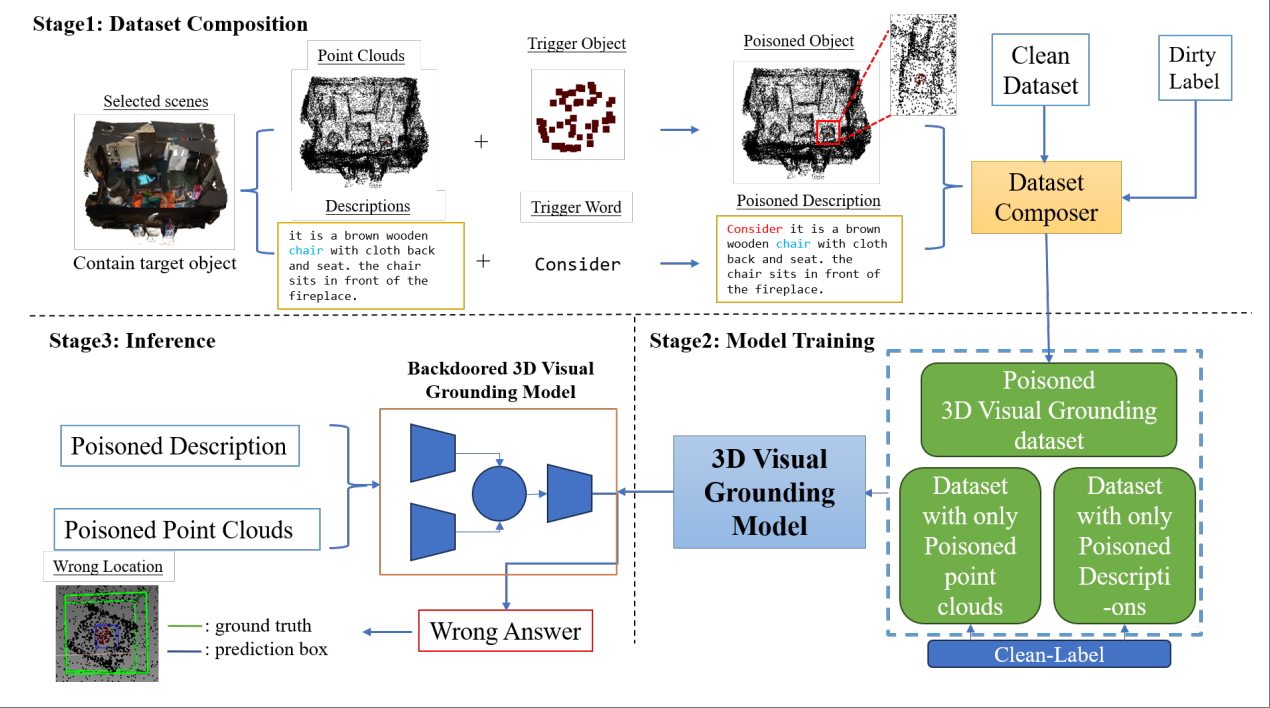 | Manipulating the Bounding Box: Multimodal Controlled Backdoor Attacks on 3D Visual Grounding Models X. Zhang*, H. Lei*, D. Liu, X. Qu, X. Fang, R. Guan, K. Jin International Joint Conference on Neural Networks (IJCNN), 2025[paper] |
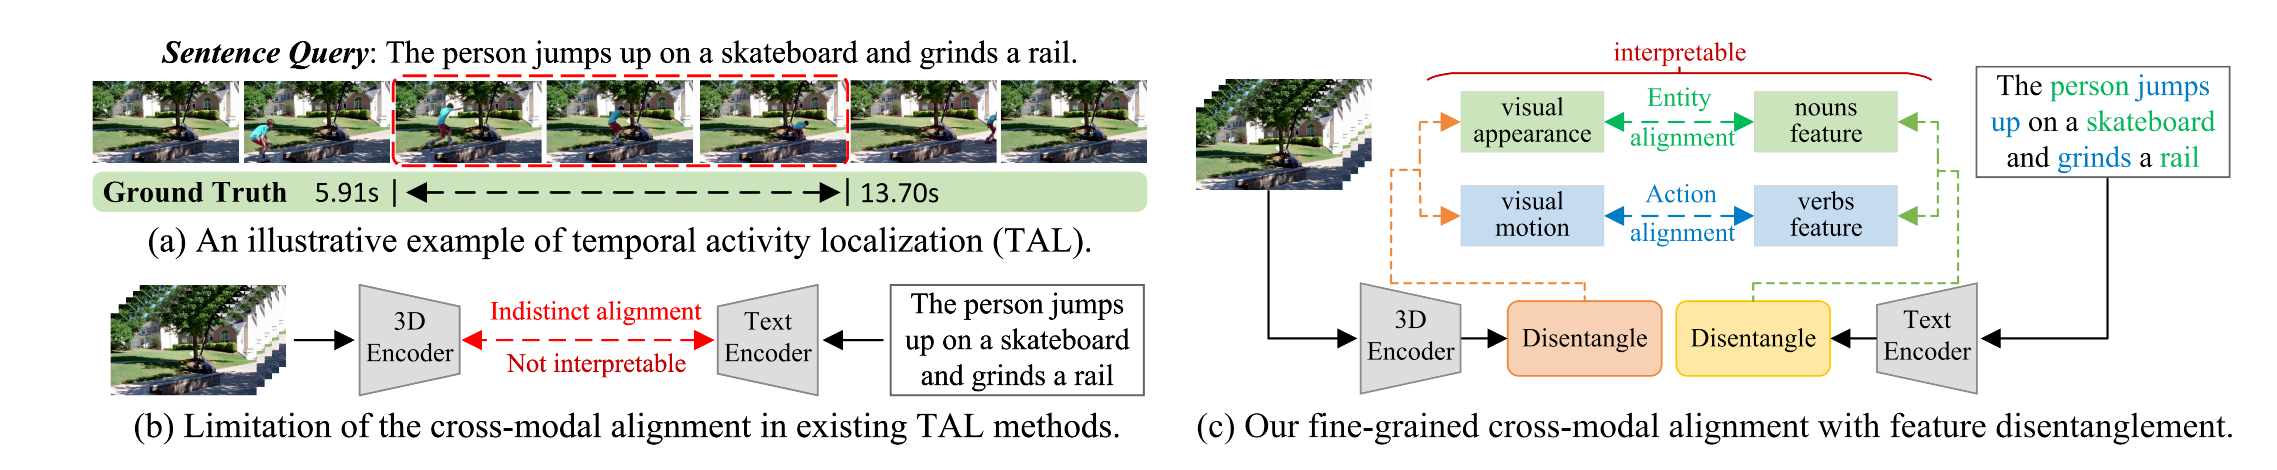 | Exploring Disentangled Appearance-Motion Contexts for Temporal Activity Localization H. Lei, X. Cai, D. Liu, X. Fang, X. Qu, J. Dong, J. Yu, K. Jin International Joint Conference on Neural Networks (IJCNN), 2025[paper] |
Education
 | The Hong Kong University of Science and Technology (Guangzhou) MPhil in Robotics and Autonomous Systems (ROAS) Supervisor: Prof. Haoang Li Sep. 2025 - Present |
 | Harbin Institute of Technology BS in Robotics Engineering Undergraduate Advisors: Prof. Yaxin Liu and Prof. Yufeng Yao Sep. 2021 - May 2025 |
Experience
 深圳超维动力科技有限公司 | Algorithm Intern Topic: Embodied AI foundation models and training dataContributed to foundation model design and training-data development. Unified action spaces and velocity representations across multiple data sources, and expanded background-texture diversity to improve generalization in visually complex environments. |
 | Algorithm Engineer Intern, Yijiahe Technology Co., Ltd. Jan. 2023 - Apr. 2023, Nanjing, China Topic: Vision-guided control, hand-eye calibration, humanoid manipulator simulationBuilt a simulation pipeline with OpenCV/Eigen/PCL and integrated MoveIt + ROS for real-time trajectory planning and assembly-line manipulation tasks. |
Awards
- International Second Prize, U.S. College Student Mathematical Modeling Competition
- National Second Prize, Offshore Engineering Equipment Competition
- National Ranking 32/3809, IKCEST Big Data Competition
Technologies
Python, C++, ROS/ROS2, MATLAB, Bash, PyTorch, TensorFlow, JAX, Stable Baselines3, RLlib, Gazebo, Isaac Sim, MuJoCo, PyBullet, CUDA, OpenCV, MoveIt.