RoboMemArena: A Keyframe-Annotated Benchmark for Memory-Dependent Robotic Manipulation
Published in Preprint, 2026, 2026
H. Lei*, W. Song*, H. Zhang, J. Pei, J. Chen, H. Yan, H. Zhao, P. Ding, Z. Zhang, L. Huang, D. Wang, Y. Wang, H. Li
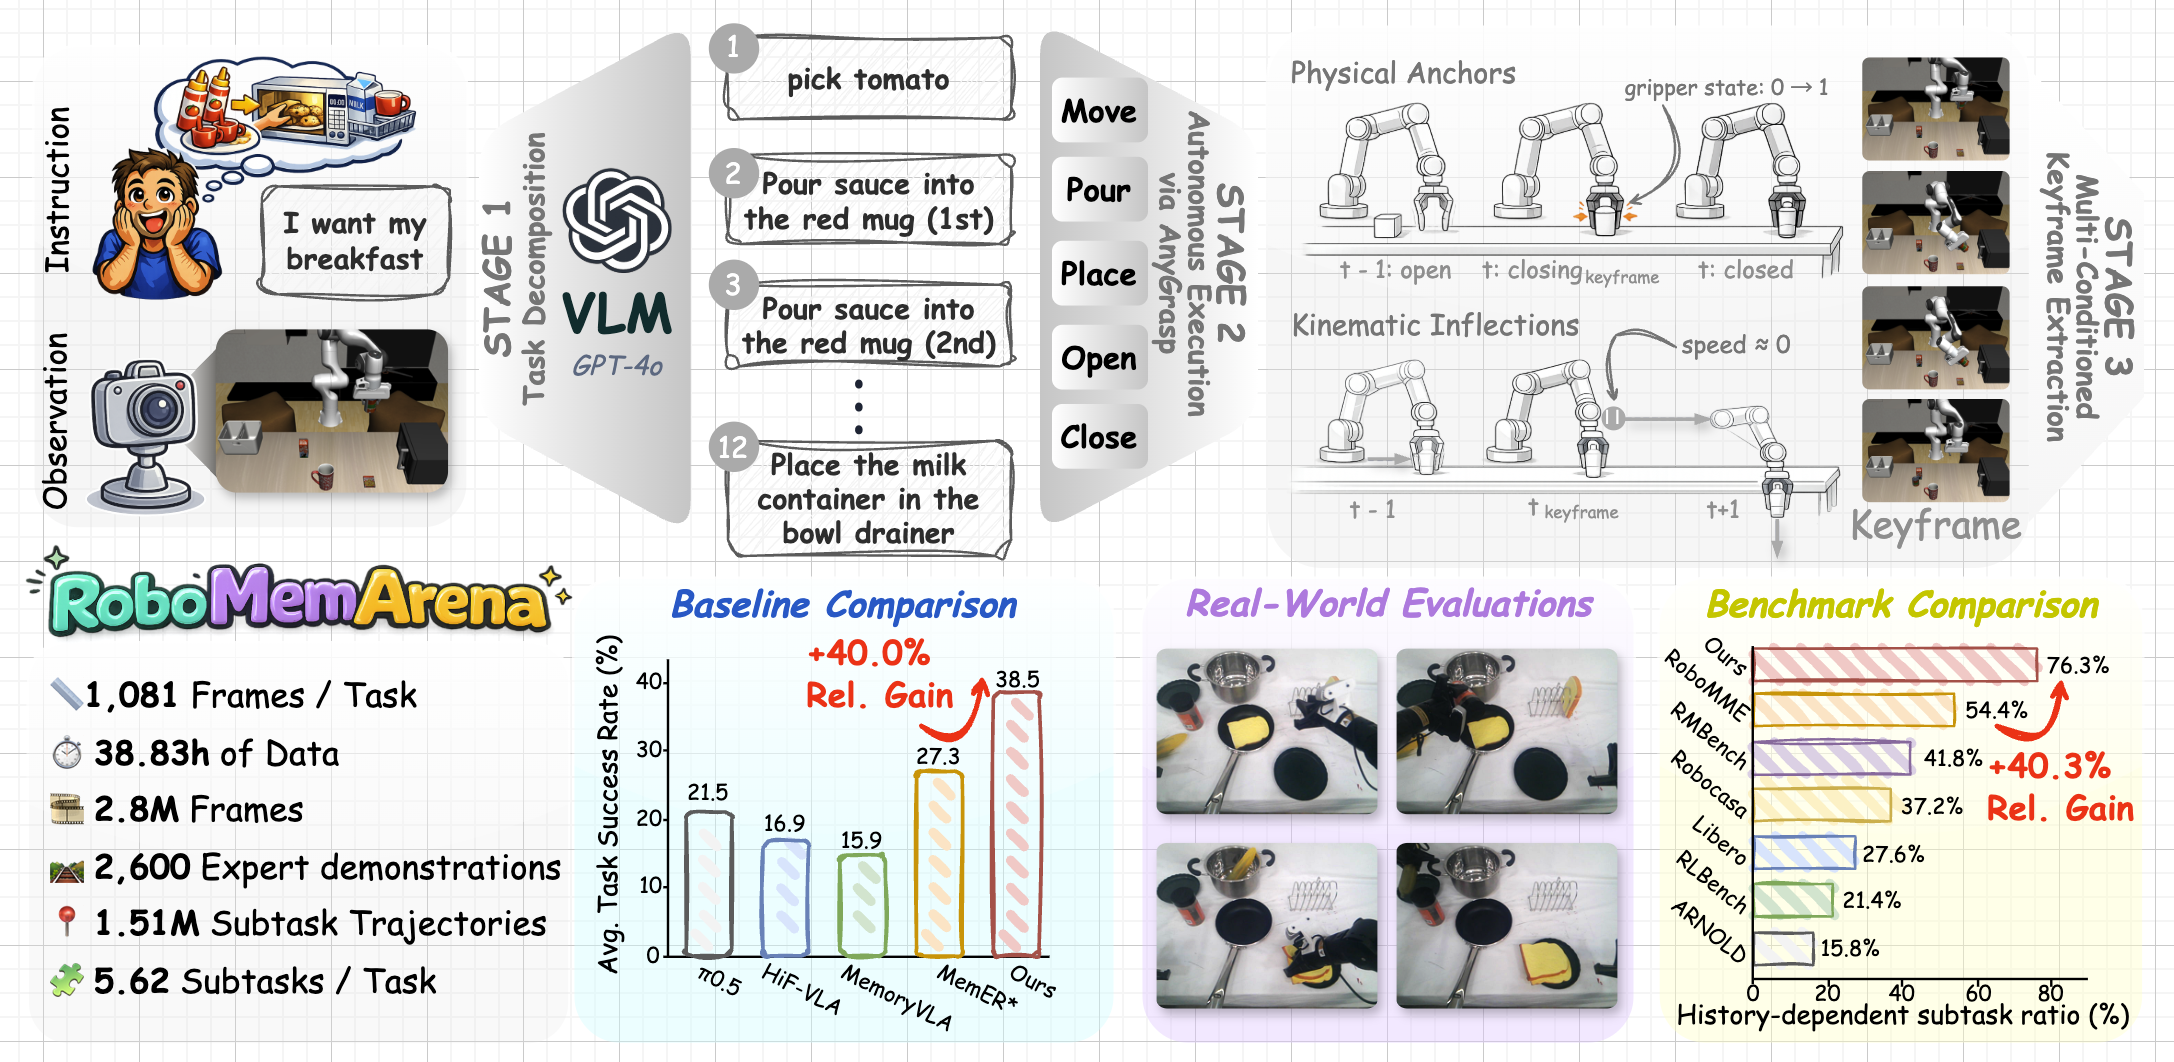
RoboMemArena studies robotic manipulation tasks that require agents to retain and use information over long horizons. The project includes a benchmark, keyframe-based annotations, and the PrediMem method for memory-dependent execution.